Develops the robotics simulation software CoppeliaSim for prototyping, validation and digital twins
Coppelia Robotics AG
New on Amplifa
About Coppelia Robotics
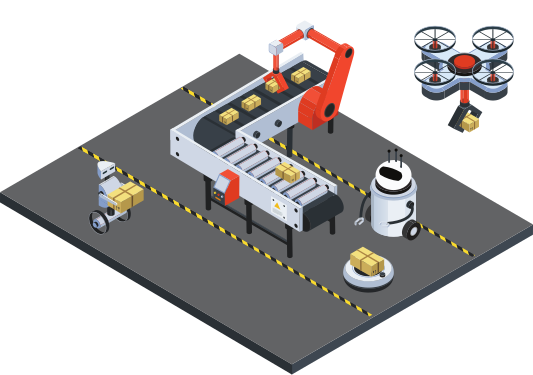
Coppelia Robotics is the developer of CoppeliaSim (formerly V-REP), a versatile and scalable robotics simulation software. The platform supports companies and research institutions in testing and validating complex robotics systems through algorithm prototyping, kinematic design and the creation of digital twins. CoppeliaSim is based on a distributed control architecture in which each object or model can be controlled individually via embedded scripts (Python or Lua), plugins (C/C++), remote API clients (including Python, Java, MATLAB, Rust) or custom solutions. Fields of application include rapid algorithm development, factory automation simulations, prototyping and verification, robotics training, remote monitoring and safety double-checking. In addition to the software, the company offers tailored solutions such as model creation and plugin development, personalized training and e-mail support. Users include companies from robotics and automation, research institutions as well as schools and universities.
- Processes
- Factory Automation Simulation, Fast Prototyping and Verification (software-based), Remote Monitoring / Safety Double-Checking (simulation), Simulation of paint or welding seams, Model Creation and Specialized Plugin Development (Customized Solutions), Personalized Training Sessions, Customized solutions (model creation, plugin development), Personalized training/coaching
- Materials
- CoppeliaSim (formerly V-REP), Forward/Inverse Kinematics, Physics Engines (MuJoCo, Bullet, ODE, Newton, Vortex), Path and Motion Planning, Programming Interfaces
- Industries
- Robotics/Automation, Factory automation, Research & Development, Education (schools, universities)
- 01
Requirements analysis
- 02
Model creation
- 03
Plugin development
- 04
Simulation & validation
- 05
Training & support
Software & Processes
CoppeliaSim (formerly V-REP)
Robotics simulator with distributed control architecture for prototyping, kinematics and digital twins.
Forward/Inverse Kinematics
Kinematics calculations for arbitrary mechanisms including branched and closed-loop structures.
Physics Engines (MuJoCo, Bullet, ODE, Newton, Vortex)
Five physics engines for realistic dynamics calculations such as collision behavior and grasping.
Path and Motion Planning
Flexible motion planning via the OMPL library encapsulated in a plugin.
Programming Interfaces
Five programming approaches in seven languages including ROS interfaces and ZeroMQ messaging.
Inside the production

Industries
Processes & technical limits
| Processes | Tolerance | Max. part | Weight | Lot size | Materials |
|---|---|---|---|---|---|
| Engineering | – | – | – | – | – |
| Factory Automation SimulationEngineering | – | – | – | – | – |
| Fast Prototyping and Verification (software-based)Engineering | – | – | – | – | – |
| Remote Monitoring / Safety Double-Checking (simulation)Testing | – | – | – | – | – |
| Simulation of paint or welding seamsSimulation | – | – | – | – | – |
| Model Creation and Specialized Plugin Development (Customized Solutions)Engineering | – | – | – | – | – |
| Personalized Training SessionsEngineering | – | – | – | – | – |
Additional services
Reference customers
History
- 2013
Publication 'CoppeliaSim (formerly V-REP): a Versatile and Scalable Robot Simulation Framework' at IROS 2013
CoppeliaSim was formerly called V-REP; 100% compatible with V-REP, runs faster and with more features