Open-source software platform based on ROS and ROS 2 for the automation of manufacturing and industrial robotics
ROS-Industrial (ROS-I Consortium)
San Antonio, TX (USA, SwRI) · Stuttgart (DE, Fraunhofer IPA) · Singapore (ARTC/NTU)New on Amplifa
About ROS-Industrial
ROS-Industrial is an open-source project that extends the capabilities of the Robot Operating System (ROS) to industrial hardware and applications in manufacturing automation. The project was initiated in January 2012 by Shaun Edwards at the Southwest Research Institute (SwRI) in San Antonio, as a collaboration between Yaskawa Motoman, SwRI and Willow Garage. The affiliated ROS-Industrial Consortium Americas launched in March 2013 under the leadership of SwRI; regional consortia followed in Europe (Fraunhofer IPA, Stuttgart) and in the Asia-Pacific region (ARTC/NTU, Singapore). The project develops interfaces and drivers for industrial robots, sensors, grippers and automation technology as well as capabilities such as motion planning, perception and calibration. The Consortium provides a technical roadmap process, code quality standards, training, technical support and joint development projects. Fields of application include manufacturing automation, logistics, aerospace, construction, agricultural technology, foundry and medical technology.
- Site
- San Antonio, TX
- Processes
- Robotic Blending (robot-assisted grinding/refinishing, foundry application), Logistics automation with AMRs (Autonomous Mobile Robots) for inventory/kitting processes, Tactile Robotic Assembly, Closed-loop manufacturing for composites (SAM|XL), Training and technical support for ROS/ROS 2 in manufacturing automation, Open-source software for industrial automation (ROS/ROS 2), Training, Technical support
- Materials
- Cast steel/steel casting (foundry application, no specifically named alloy), ROS/ROS 2 Software Framework, Unified Robot Description Format, Robotic Blending
- Founded
- 2012
- Industries
- Manufacturing automation, Logistics, Aerospace, Construction, Agricultural technology, Foundry
- 01
Roadmapping
- 02
Open-source development
- 03
Code quality review
- 04
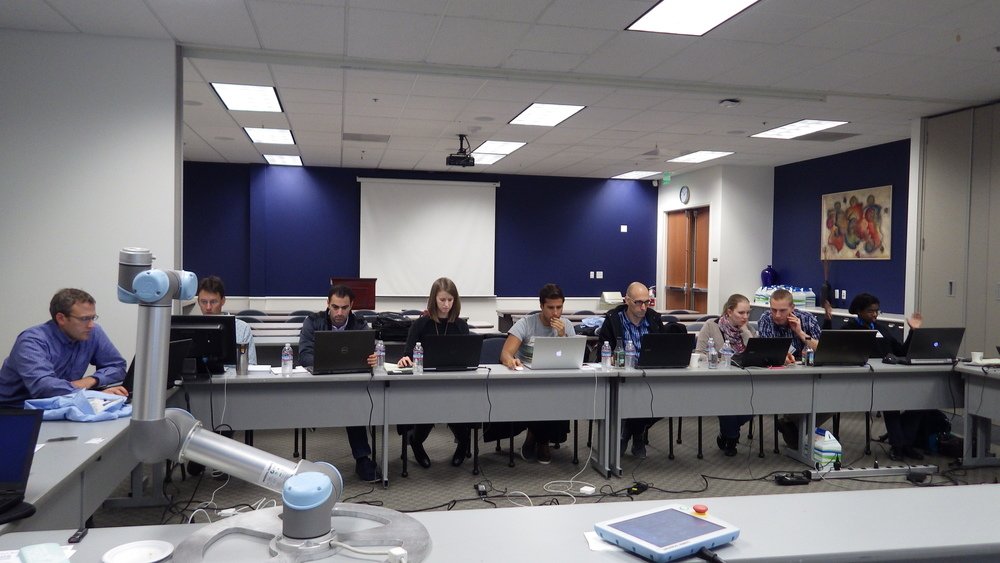
Training & Support
- 05
Joint development projects
Software & Applications
ROS/ROS 2 Software Framework
Open Robot Operating System as a foundation for industrial robotics and manufacturing automation, BSD/Apache licensed.
Unified Robot Description Format
Description format for robot models with industrial driver libraries and interfaces.
Robotic Blending
Robot-assisted grinding and post-processing, developed in part with the Steel Founders' Society of America for foundry applications.
Regional Consortia & Locations
San Antonio, TX
USHome of ROS-I Consortium Americas / Southwest Research Institute
Stuttgart
DEROS-I Consortium Europe (Fraunhofer IPA)
Singapore
SGROS-I Consortium Asia Pacific (ARTC/NTU)
Inside the production
Industries
Processes & technical limits
| Processes | Tolerance | Max. part | Weight | Lot size | Materials |
|---|---|---|---|---|---|
| Robotic Blending (robot-assisted grinding/refinishing, foundry application)Surface | – | – | – | – | – |
| Logistics automation with AMRs (Autonomous Mobile Robots) for inventory/kitting processesAssembly | – | – | – | – | – |
| Engineering | – | – | – | – | – |
| Tactile Robotic AssemblyAssembly | – | – | – | – | – |
| Closed-loop manufacturing for composites (SAM|XL)Engineering | – | – | – | – | Composites |
| Training and technical support for ROS/ROS 2 in manufacturing automationEngineering | – | – | – | – | – |
Additional services
Reference customers
History
- 2012
Launch of the ROS-Industrial GitHub repository in January 2012 by Shaun Edwards at SwRI; collaboration of Yaskawa Motoman, SwRI and Willow Garage
- 2013
Launch of the ROS-Industrial Consortium Americas (March 2013) under the leadership of SwRI; later consortia in Europe (Fraunhofer IPA) and Asia-Pacific (ARTC/NTU)
- 2018
Collaboration with Microsoft and BMW on flexible logistics automation
- 2022
ROS-Industrial has been active for over 10 years