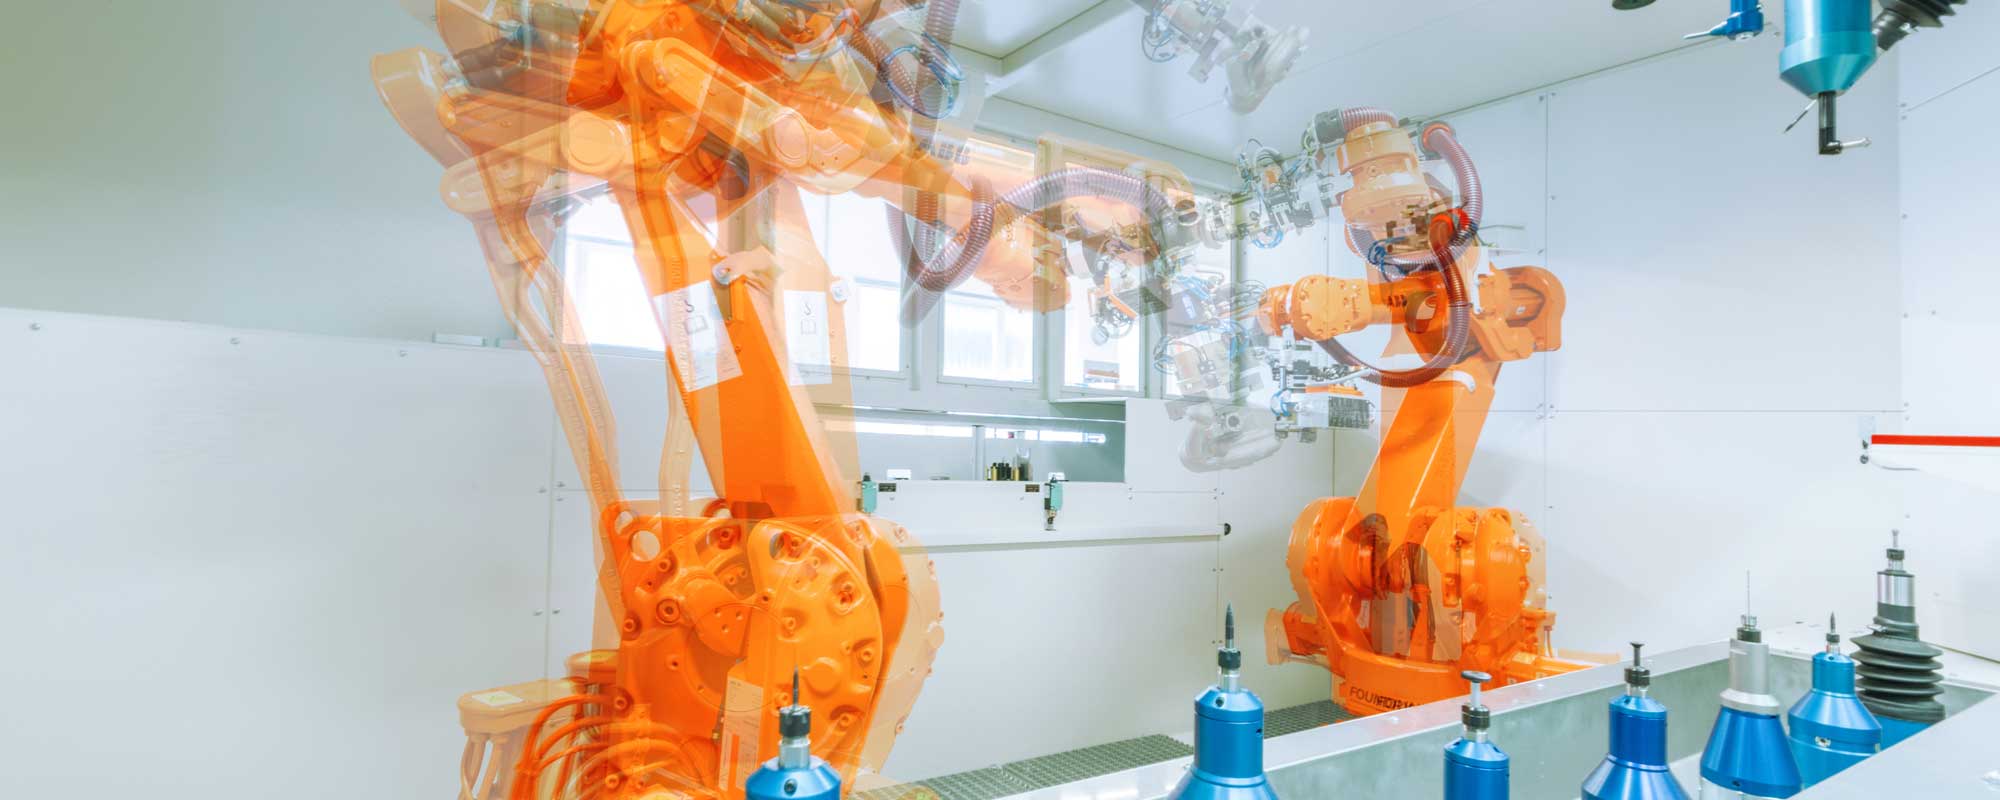
Systems for automated deburring, handling and robot automation – from tools to machines to turnkey systems
WMS-engineering Werkzeuge-Maschinen-Systeme GmbH
Klettgau-Grießen (headquarters) · Nordstemmen (WMS Robotics GmbH) · Colmar (FR) · Whitmore Lake, MI (US) · Torino (IT) · Prague (CZ)New on Amplifa
About WMS-engineering
WMS-engineering Werkzeuge-Maschinen-Systeme GmbH is a provider specializing in robot automation with core competence in deburring with defined geometry. The company develops and manufactures flexible deburring spindles, standardized special machines and complete systems from single cells to production lines. Robot cells based on a modularly expandable platform system are complemented by washing, measuring, palletizing, bin picking and cobot applications. In addition to systems engineering, WMS offers manufacturing services for precision-mechanical components on its own turning and milling centers, electrical planning, assembly manufacturing, custom grippers, and 3D printing of prototypes and gripper fingers made of polyamide. Customers come primarily from the automotive and engine industries as well as mechanical engineering, including BMW, Bosch, Daimler and John Deere; materials processed include aluminium, steel and high-alloy metals. The headquarters is located in Klettgau-Grießen in the Waldshut district, with around 3,500 m² including an assembly hall and training workshop; subsidiaries and sales partners exist in France, the USA, Italy and the Czech Republic.
- Site
- Klettgau-Grießen
- Processes
- Deburring by robot automation (mechanical deburring with defined geometry), Workpiece-guided deburring (robot guides the component to the tools), Tool-guided deburring (robot guides the tools to a fixed workpiece), Grinding, Dressing, Handling (robot handling), Washing (wet processing as an extension of the deburring cell), Measuring (modular extension of the deburring system)
- Materials
- Aluminium, High-alloy metals, Steel, PA (polyamide, for 3D printing of prototypes/gripper fingers), Polyamide (PA)
- Industries
- Automotive industry, Mechanical engineering, Engine and drive technology,
- 01
Project and process planning
- 02
Design (basic bodies made of steel square profiles)
- 03
Spindle and tool manufacturing (turning, milling, 3D printing)
- 04
Electrical planning, installation and programming
- 05
Assembly of the systems (assembly hall)
- 06
Commissioning as a turnkey system
- 07
Remote maintenance as well as spare parts and maintenance management
Materials and processes
Aluminium
Processed in deburring cells, e.g. for exhaust manifolds, pistons and wheel rims.
Steel
Material for deburring, grinding and dressing tasks as well as for machine basic bodies made of steel square profiles.
High-alloy metals
Used for demanding components such as turbine blades and turbochargers.
Polyamide (PA)
Material for in-house printed prototypes and gripper fingers.
Locations
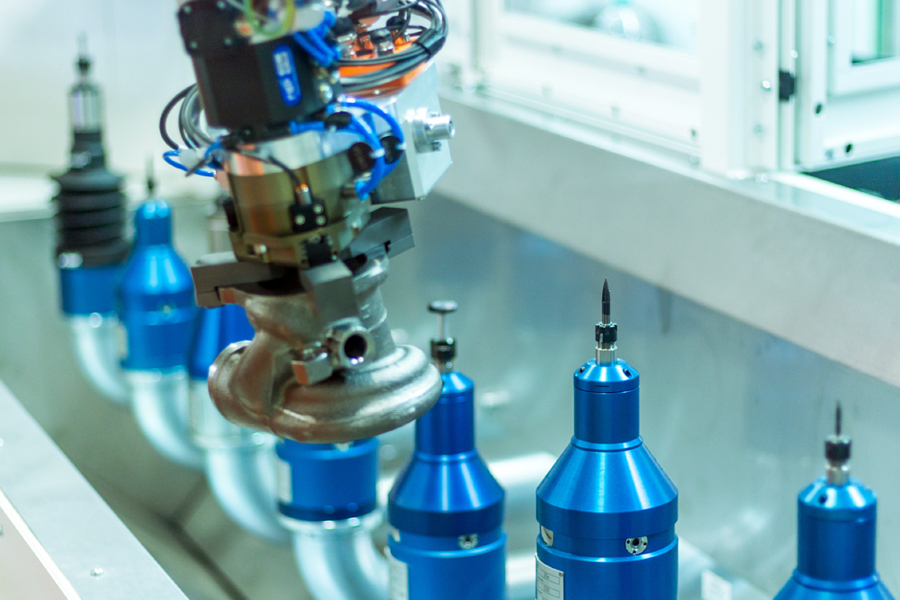
Klettgau-Grießen
DEHeadquarters with manufacturing, assembly and training workshop
- Part weight / size
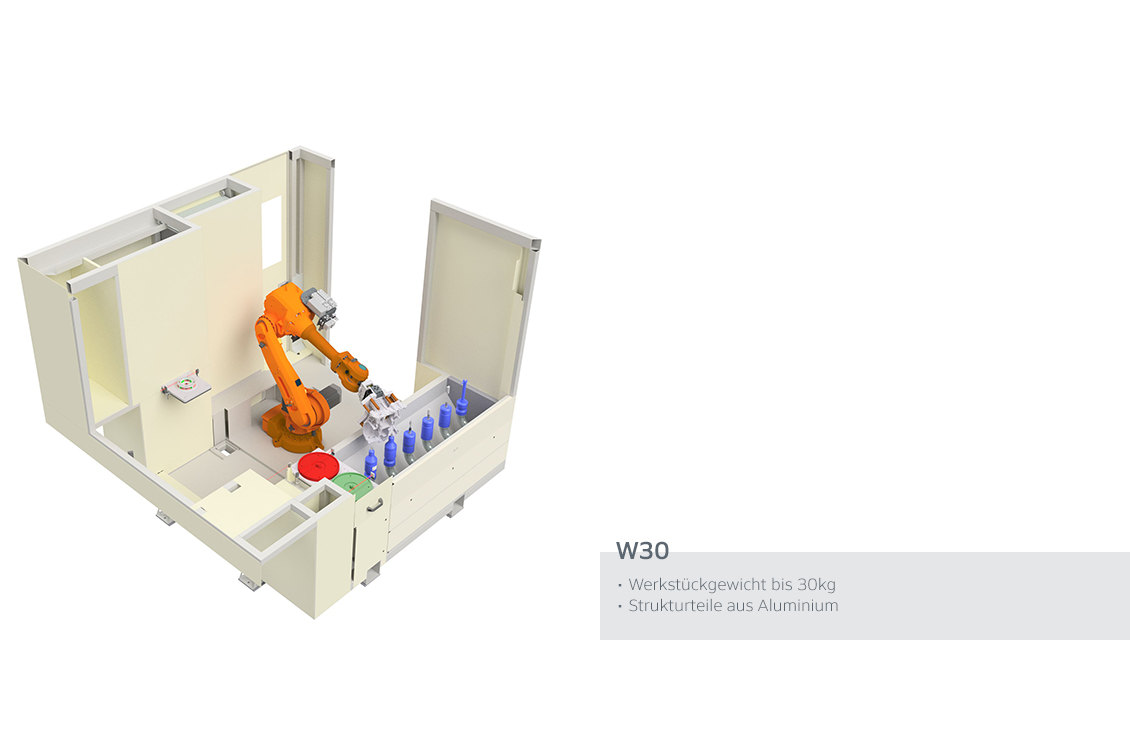
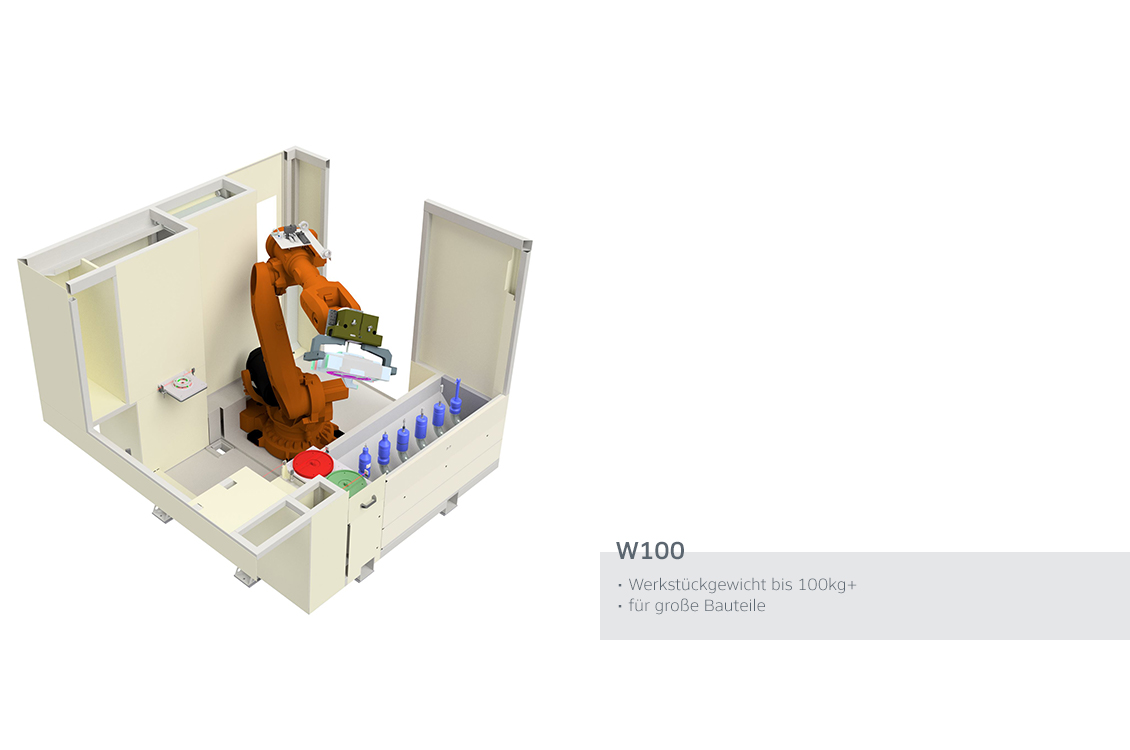
- Components up to 30 kg (W30), W100 for heavy parts
- Lot size
- Single system to production line
- Materials
- Aluminium, steel, high-alloy metals, PA
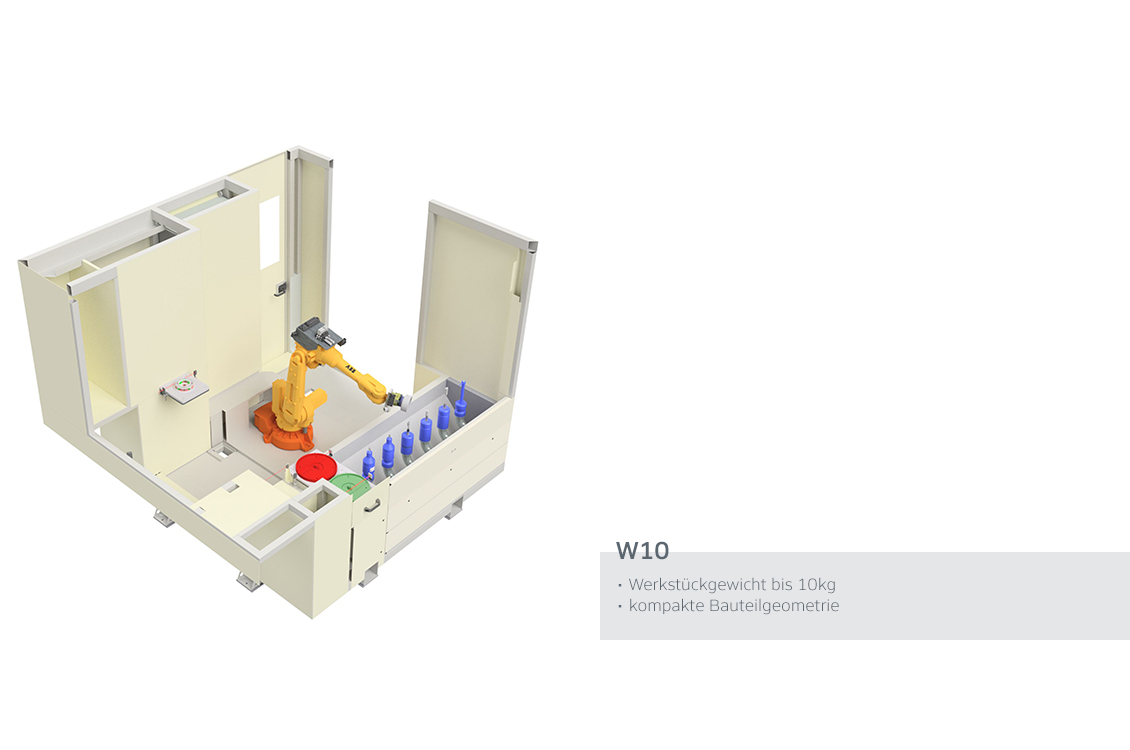
- Robot deburring cells W10, W10 TWIN, W30, W30 SINGLE, W30 TWIN/TWIN+, W100
- Turning centers
- Milling centers
- 3D printers
Nordstemmen
DEBranch office WMS Robotics GmbH
Colmar
FRBranch office France
Whitmore Lake, MI
USSales partner Creative Automation Inc.
Torino
ITSales partner Simu s.r.l.
Prag
CZSales partner Newtech s.r.o.
Inside the production
Industries
Processes & technical limits
| Processes | Tolerance | Max. part | Weight | Lot size | Materials |
|---|---|---|---|---|---|
| Deburring by robot automation (mechanical deburring with defined geometry)Surface | – | – | – | – | Aluminium, High-alloy metals, Steel |
| Workpiece-guided deburring (robot guides the component to the tools)Surface | – | – | – | – | – |
| Tool-guided deburring (robot guides the tools to a fixed workpiece)Surface | – | – | – | – | – |
| GrindingSurface | – | – | – | – | Aluminium, High-alloy metals, Steel |
| DressingSurface | – | – | – | – | Aluminium, High-alloy metals, Steel |
| Handling (robot handling)Assembly | – | – | – | – | – |
| Washing (wet processing as an extension of the deburring cell)Surface | – | – | – | – | – |
| Measuring (modular extension of the deburring system)Testing | – | – | – | – | – |
| Palletizing (modular extension of the deburring system)Assembly | – | – | – | – | – |
| Bin picking (extracting unsorted parts from crates/pallet boxes)Assembly | – | – | – | – | – |
| Cobot applications (collaborative robots)Assembly | – | – | – | – | – |
| Manufacturing of precision-mechanical components (single part/small series, contract manufacturing)Machining | – | – | – | – | – |
| Turning (in-house turning centers)Machining | – | – | – | – | – |
| Milling (in-house milling centers)Machining | – | – | – | – | – |
| Manufacturing of assemblies and custom gripping techniquesAssembly | – | – | – | – | – |
| Electrical concepts: planning, installation and programmingEngineering | – | – | – | – | – |
| Special machine construction / process and project planning (turnkey systems)Engineering | – | – | – | – | – |
| 3D printing of prototypes and gripper fingers made of PAAdditive | – | – | – | – | PA |
16 Anlagen & Maschinen
| Machine | Manufacturer / model | Quantity | Working area | Year built | Site |
|---|---|---|---|---|---|
| Robot deburring cell W10 | WMS-engineering W10 | – | – | – | Klettgau-Grießen |
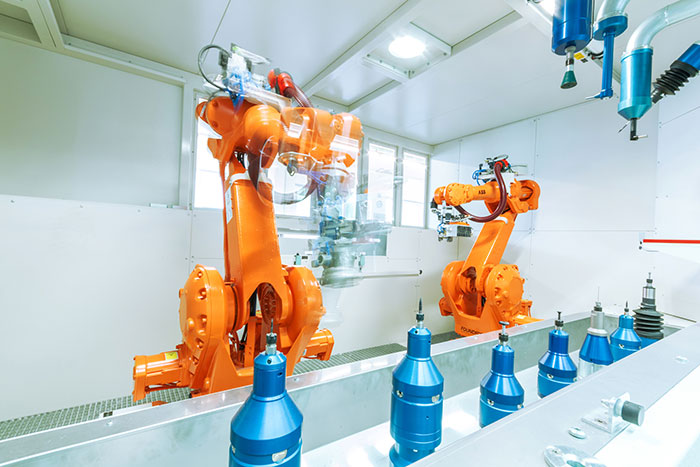
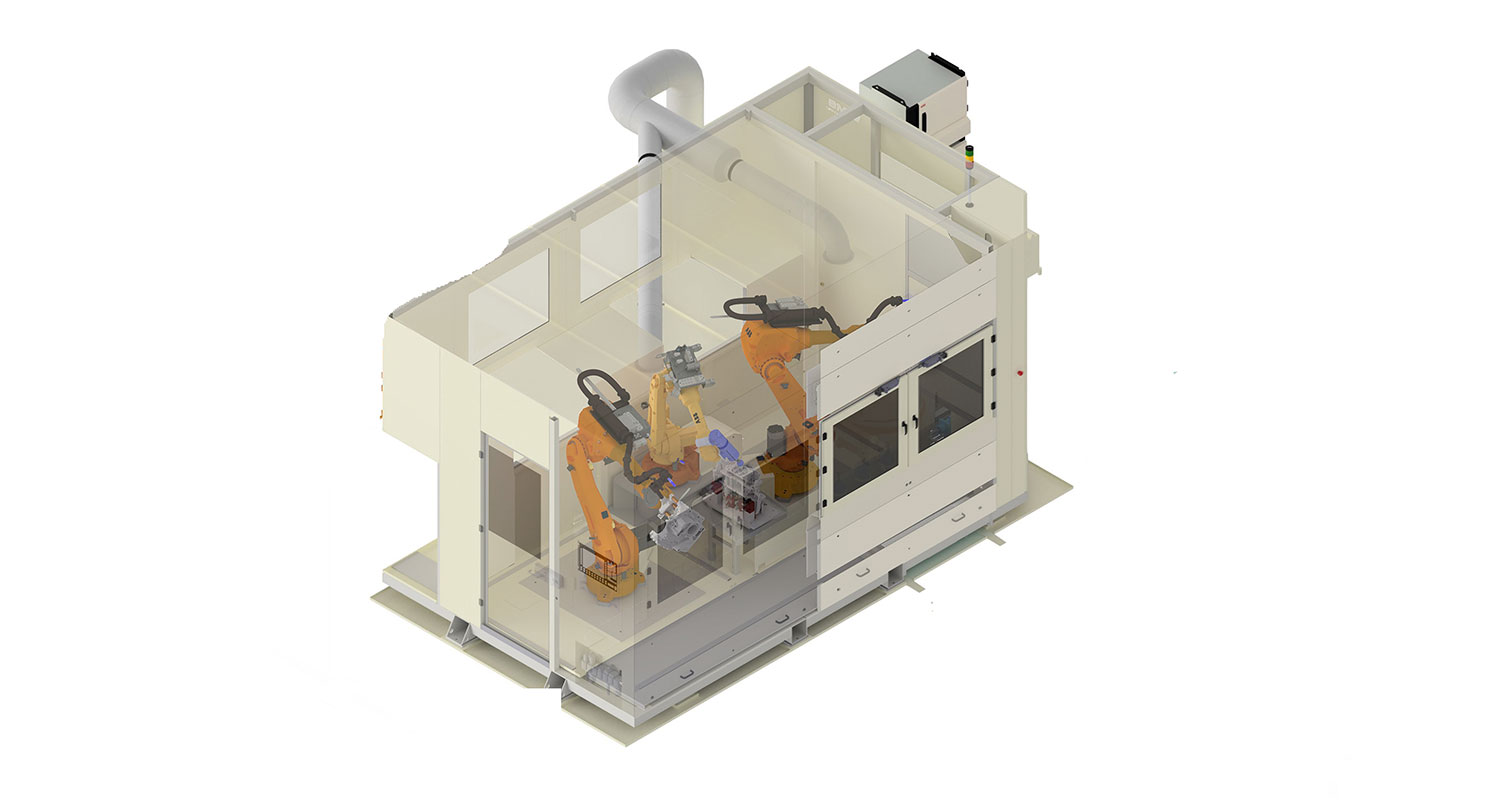
| Robot deburring cell W10 TWIN (2 collaborative robots, components up to 10 kg) | WMS-engineering W10 TWIN | – | – | – | Klettgau-Grießen |
| Robot deburring cell W30 | WMS-engineering W30 | – | – | – | Klettgau-Grießen |
| Robot deburring cell W30 SINGLE | WMS-engineering W30 SINGLE | – | – | – | Klettgau-Grießen |
| Robot deburring cell W30 TWIN / W30 TWIN+ (components up to 30 kg) | WMS-engineering W30 TWIN+ | – | – | – | Klettgau-Grießen |
| Robot deburring cell W100 | WMS-engineering W100 | – | – | – | Klettgau-Grießen |
| Handling cell for round components up to 30 kg | WMS-engineering | – | – | – | Klettgau-Grießen |
| Milling spindle 30e (electric) | WMS-engineering 30e | – | – | – | – |
| Milling spindle 30r (pneumatic) | WMS-engineering 30r | – | – | – | – |
| Slow-running tool 34f / 34h / 34c | WMS-engineering 34f, 34h, 34c | – | – | – | – |
| Axial brush 37c | WMS-engineering 37c | – | – | – | – |
| Angle cutter 35b | WMS-engineering 35b | – | – | – | – |
| Blow-off lance | WMS-engineering | – | – | – | – |
| Turning centers (in-house manufacturing) | – | – | – | – | Klettgau-Grießen |
| Milling centers (in-house manufacturing) | – | – | – | – | Klettgau-Grießen |
| 3D printers (prototypes and gripper fingers made of PA in-house) | – | – | – | – | Klettgau-Grießen |
Additional services
Reference customers
History
- 1986
SIG-Robotics invents the first flexible robot deburring tools and files a patent for them – still the basis of WMS spindles today
- 1987
Patenting of the spindle technology
- 1992
Foundation of WMS-engineering by three former SIG employees as a management buy-out
- 1996
WMS takes over SIG Robotics including all business and patents
- 2006
Expansion into the company's own premises in Klettgau-Grießen (3,500 m²)