Development and deployment of the wheeled humanoid robot FA-L with Embodied-AI platform for industrial manipulation tasks
Anigon Humanoid Robotics
Switzerland (development) · Service network EuropeNew on Amplifa
Platform for Embodied Intelligence
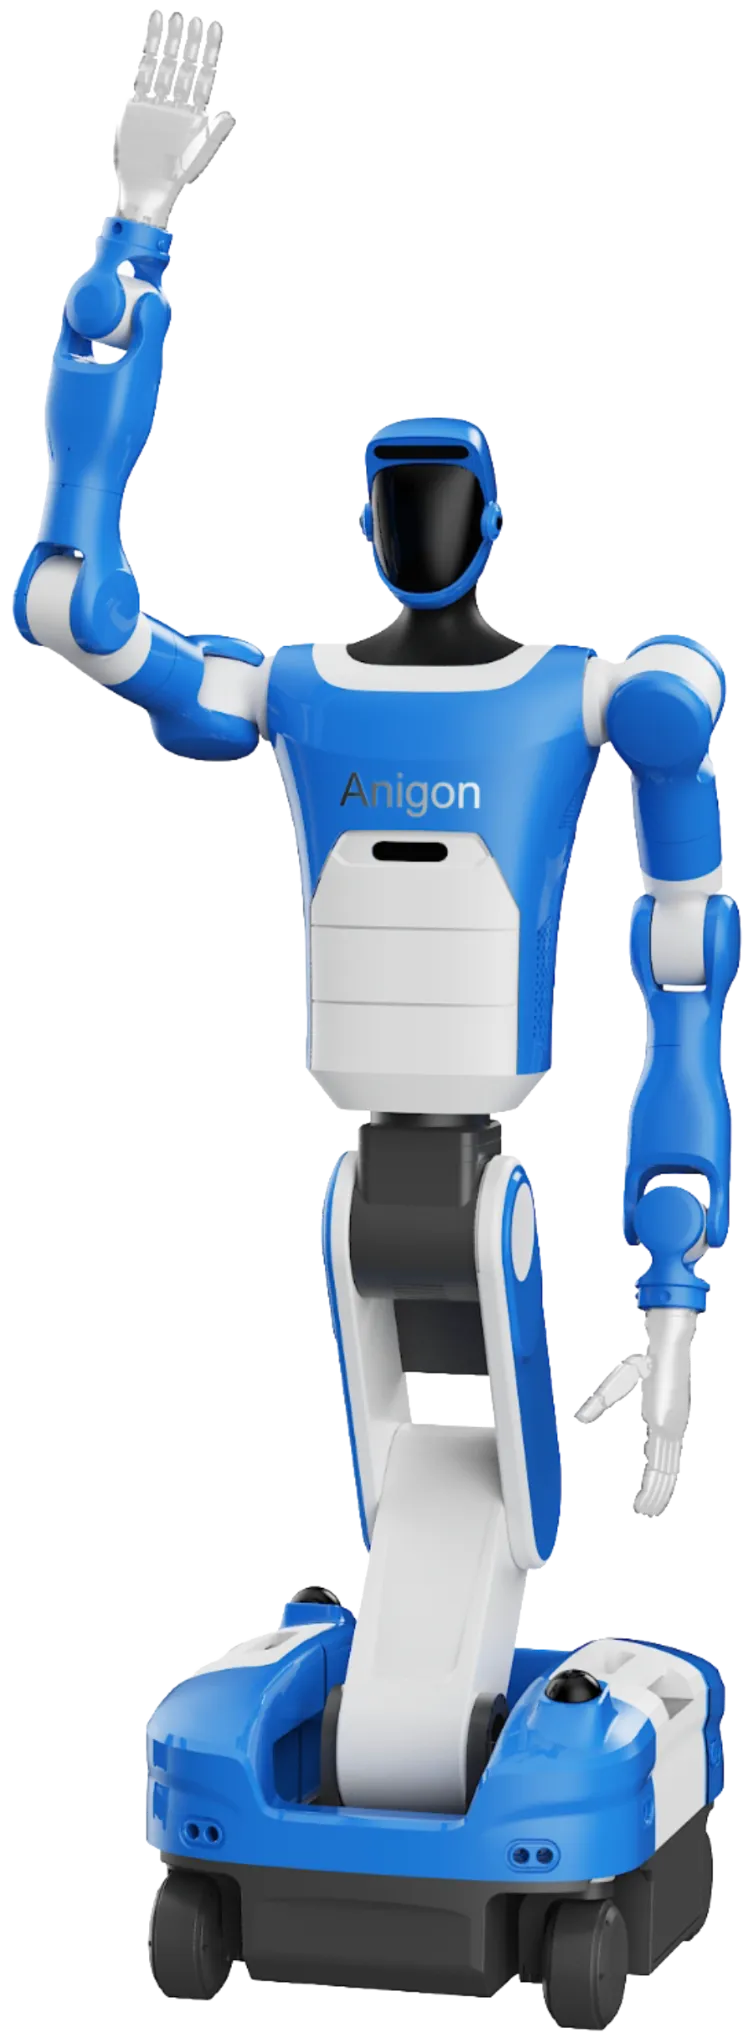
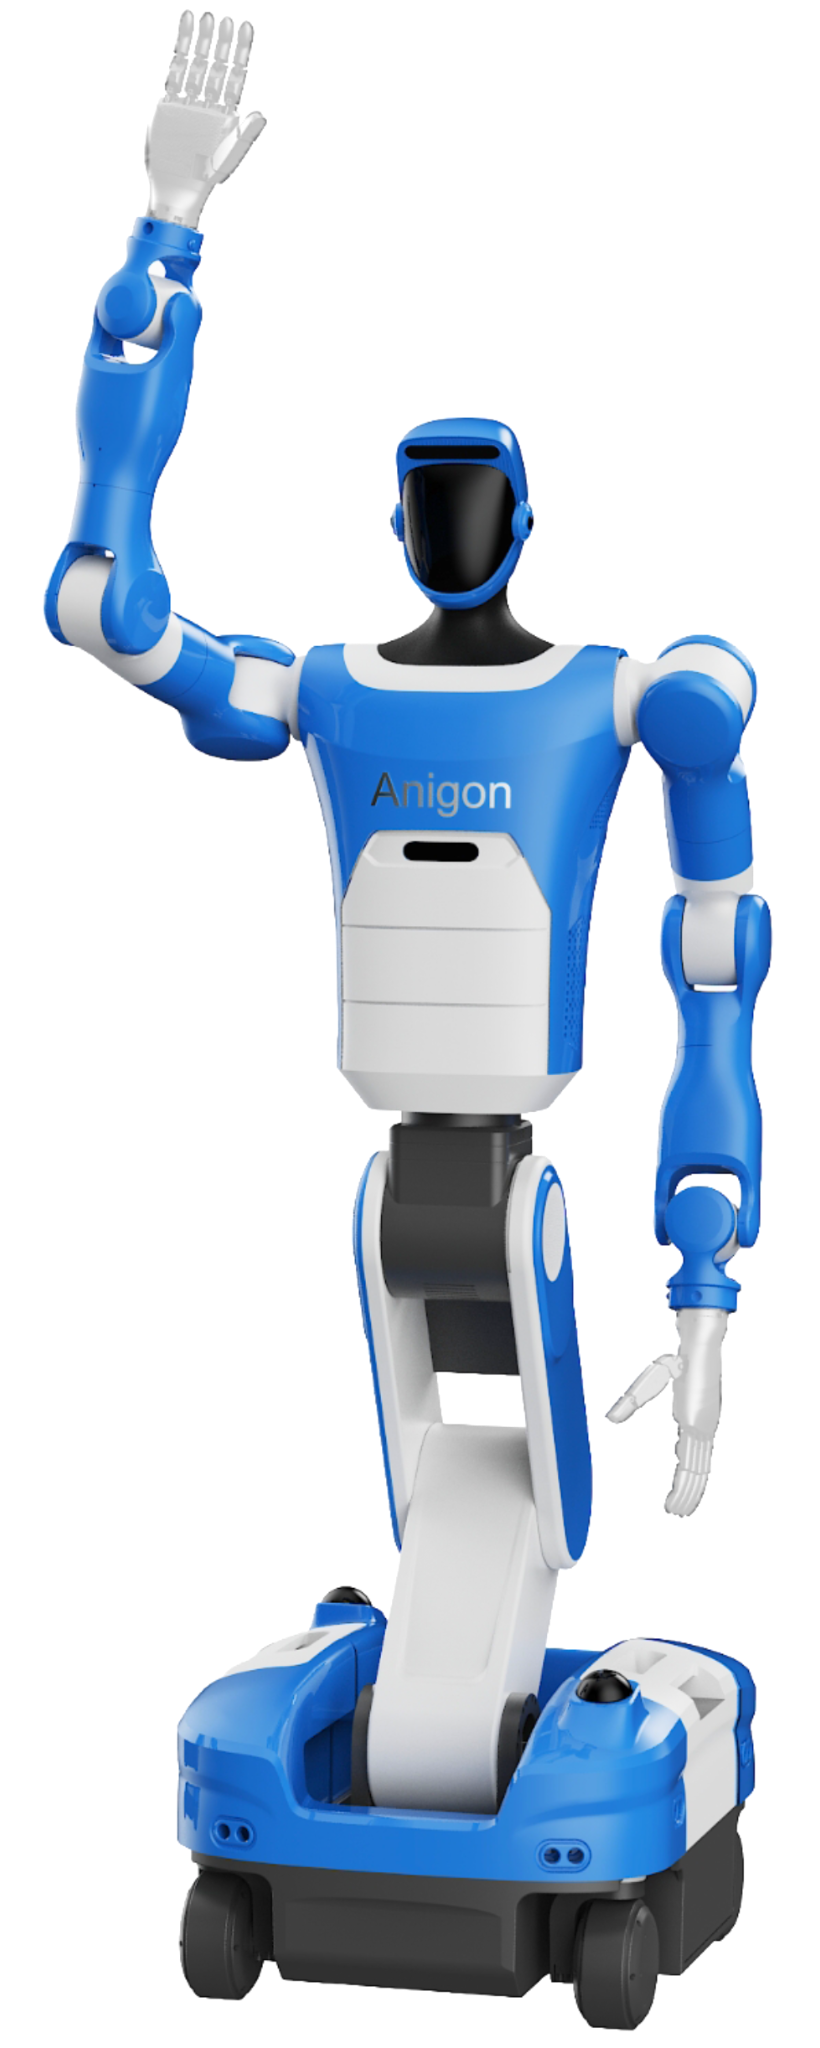
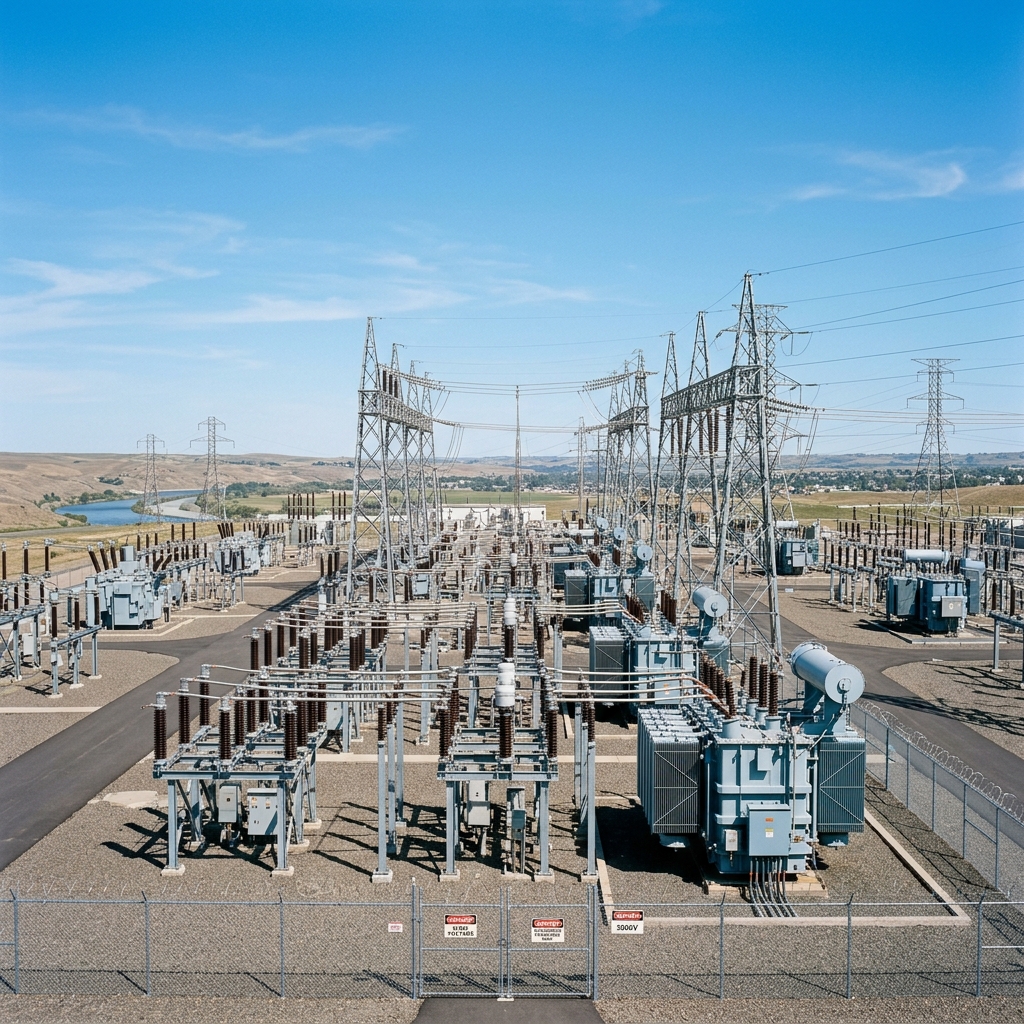
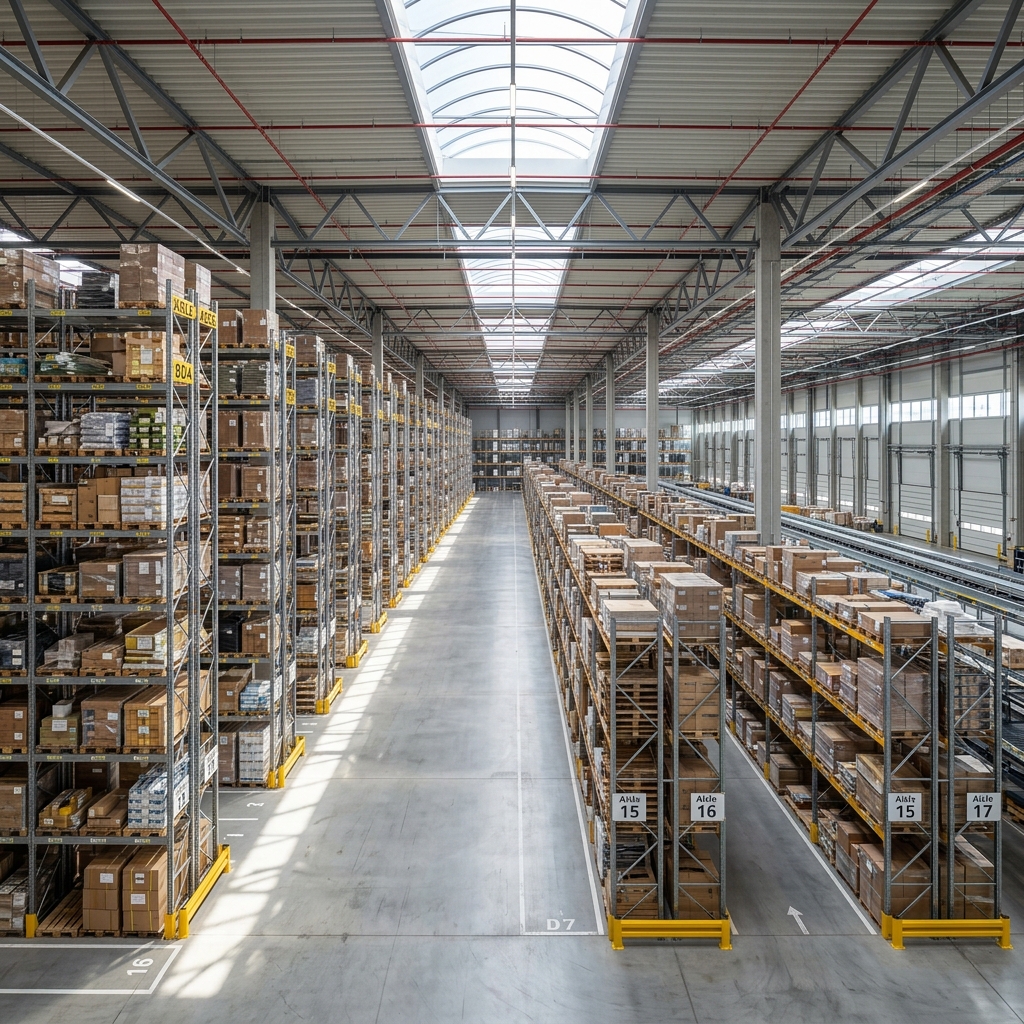
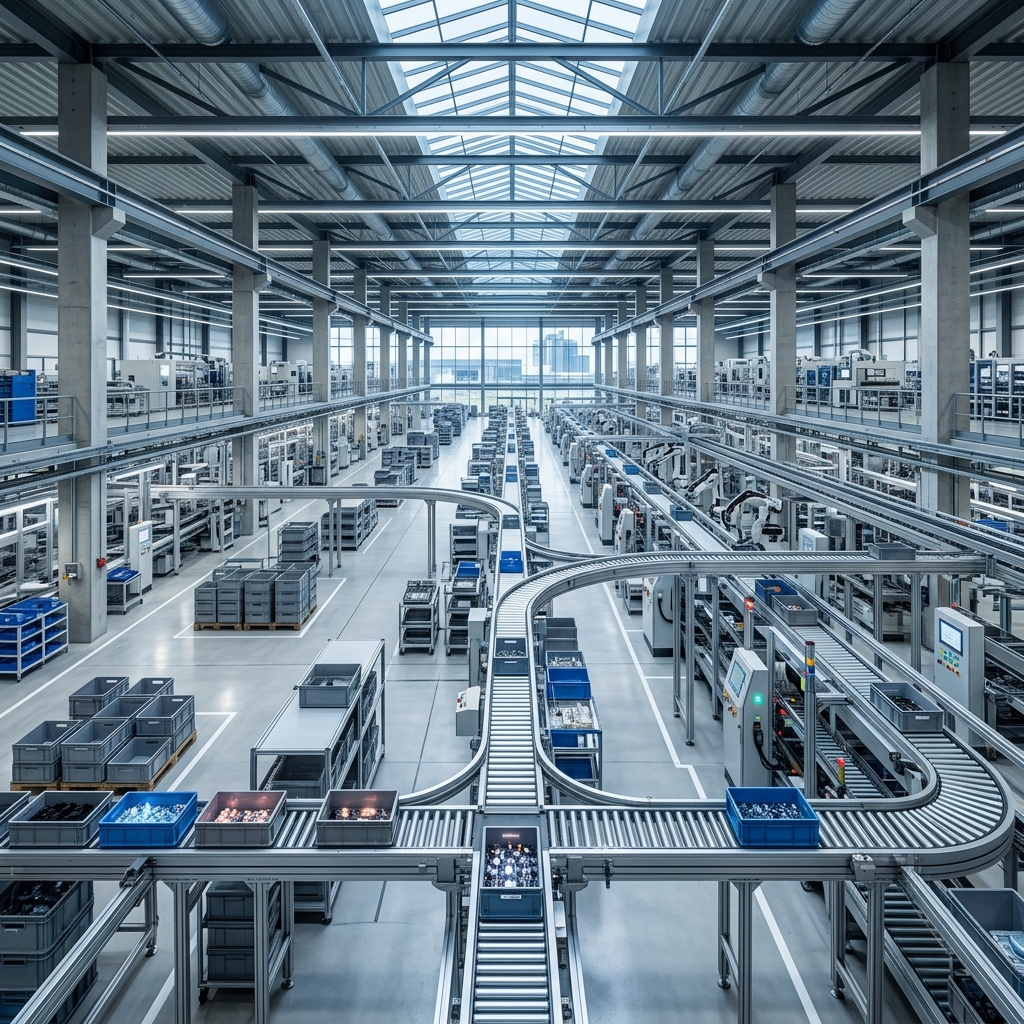
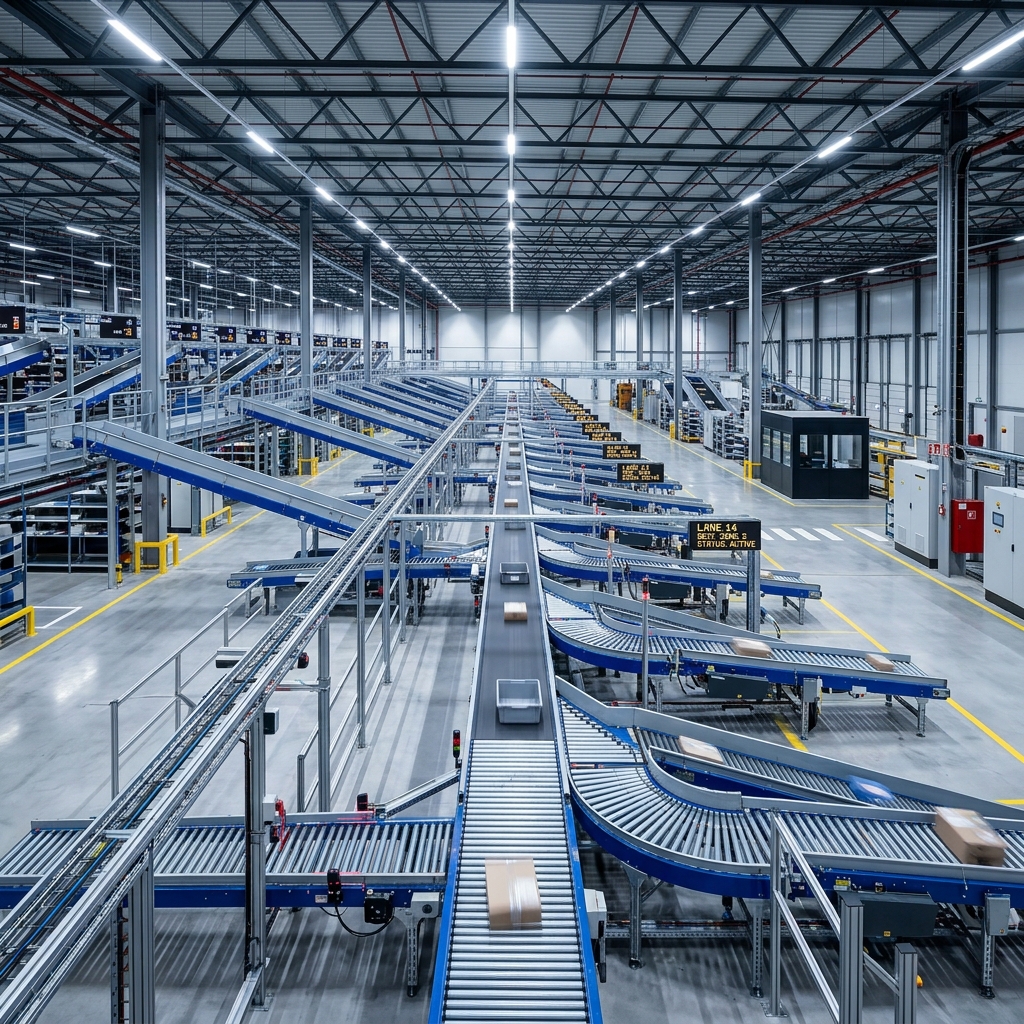
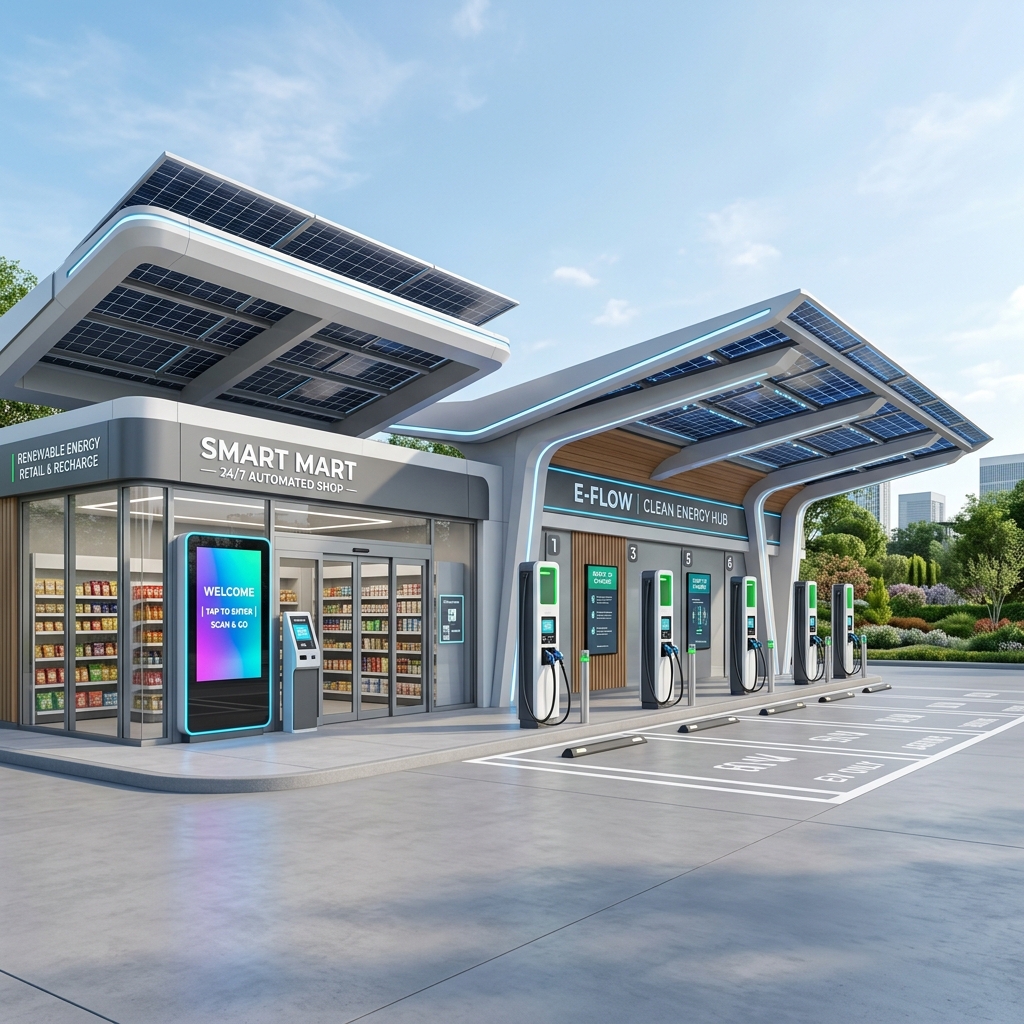
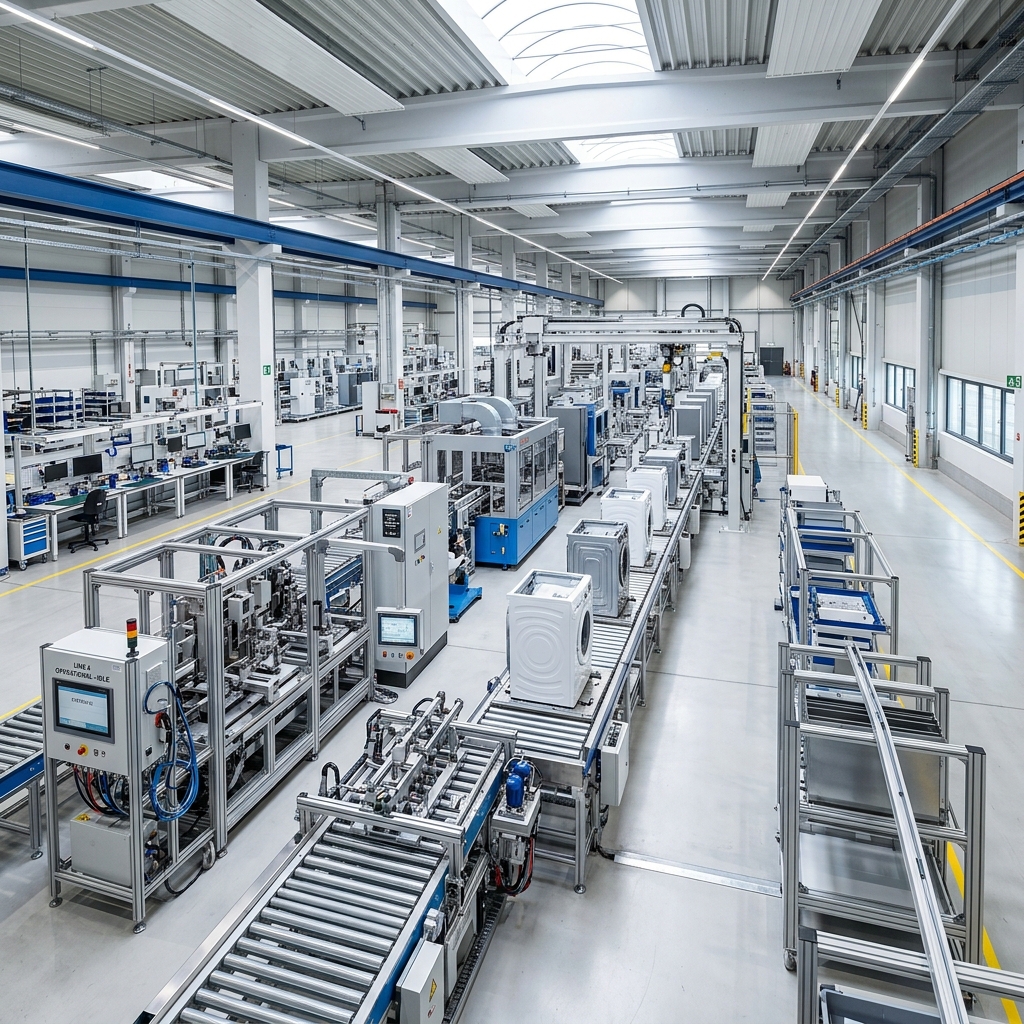
ANIGON Humanoid Robotics develops an integrated platform for Embodied Intelligence in Switzerland, consisting of robotics hardware, foundation models, data technology and deployment services. The core product is the wheeled humanoid robot FA-L with 28 degrees of freedom (full-body), dual-arm manipulation, adaptive mobile chassis, dual hot-swap batteries for 24/7 operation, as well as tactile and torque sensors with a local edge-compute controller. The platform includes the manipulation foundation models FAM (few-shot adaptation with 3–5 real demonstrations), VLTA (Vision-Language-Tactile-Action for contact-intensive manipulation), the predictive world model BridgeV2W and Human-in-the-Loop Reinforcement Learning. Deployment services include task assessment, data collection, model adaptation, system integration with open interfaces to ERP, MES and WMS, as well as continuous optimization and lifecycle maintenance. The fields of application range from autonomous material handling and production-line handling to energy-station and retail services. Service coverage and data handling are designed for European operations with local edge inference.
- Site
- Switzerland (development)
- Processes
- Robot deployment (task assessment, data collection, model adaptation), System integration (ERP, MES, WMS), Continual optimization / Human-in-the-Loop RL, Lifecycle maintenance, European service capability, Local edge inference, Deployment Auditability
- Materials
- Embodied Manipulation Foundation Model, Vision-Language-Tactile-Action Model, Embodied World Model, Embodied Data Technology, Wheeled Humanoid Robot
- Certificates
- Deployment Auditability (task logs, execution replay), Safety by Design (separated safety control)
- Industries
- Power Grid / Energy Supply, Automotive Manufacturing, Appliance Manufacturing, Logistics, Industrial Material Handling, Smart Retail
- 01
Task assessment
- 02
Data collection (human-operation video, teleoperation, simulation)
- 03
Model adaptation (FAM/VLTA)
- 04
Robot deployment (FA-L)
- 05
System integration (ERP/MES/WMS)
- 06
Continual optimization / Human-in-the-Loop RL
- 07
Lifecycle maintenance
Technology and system components
Embodied Manipulation Foundation Model
Few-shot, end-to-end model for adapting to new tasks, environments and robot platforms with a few real demonstrations.
Vision-Language-Tactile-Action Model
Multimodal model for contact-intensive manipulation, slip recovery and real-time correction in visually occluded scenarios.
Embodied World Model
Predictive model for evaluating and visualizing candidate actions before execution.
Embodied Data Technology
Task-relevant data preparation with Robot-Centric Visual Flow, Task-Centric 3D Virtual View and Cross-View Data Augmentation.
Wheeled Humanoid Robot
Full-body platform with 28 DoF, dual hot-swap batteries, tactile and torque sensors for 24/7 industrial operation.
Locations
Switzerland
CHDevelopment and engineering; service coverage for Europe
- Wheeled humanoid robot FA-L (28 DoF, dual hot-swap batteries)
- Robot arms
- Dexterous Hands
- Mobile Base
- Tactile sensors
- Torque sensors
- Edge compute controller
Robotics systems
Inside the production
Industries
Processes & technical limits
| Processes | Tolerance | Max. part | Weight | Lot size | Materials |
|---|---|---|---|---|---|
| Assembly | – | – | – | – | – |
| Assembly | – | – | – | – | – |
| Assembly | – | – | – | – | – |
| Assembly | – | – | – | – | – |
| Assembly | – | – | – | – | – |
| Engineering | – | – | – | – | – |
| Engineering | – | – | – | – | – |
| Engineering | – | – | – | – | – |
| Engineering | – | – | – | – | – |
7 Anlagen & Maschinen
| Machine | Manufacturer / model | Quantity | Working area | Year built | Site |
|---|---|---|---|---|---|
| Wheeled humanoid robot (full-body 28 DoF, dual hot-swap batteries, 24/7 operation) | ANIGON FA-L | – | – | – | Designed in Switzerland; service in Europe |
| Robot arms (hardware component) | ANIGON | – | – | – | – |
| Dexterous hands (hardware component) | ANIGON | – | – | – | – |
| Mobile base (hardware component) | ANIGON | – | – | – | – |
| Tactile sensors (hardware component) | ANIGON | – | – | – | – |
| Torque sensors (hardware component) | ANIGON | – | – | – | – |
| Edge compute controller (hardware component) | ANIGON | – | – | – | – |
Additional services
Testing and traceability
Every product specification and performance figure is linked to configurable test conditions, datasets, evaluation methods and limitations (validation records). Deployment includes Deployment Auditability with task logs and execution replay, as well as Safety-by-Design with safety control separated from model inference.
| Evidence | Switzerland |
|---|---|
| Deployment Auditability (task logs, execution replay) | |
| Safety by Design (separated safety control) |